


哈尔滨工程大学智能学院,准聘副教授,现于船舶数字与智能学科创新团队从事教学科研工作。参与科工局基础科研计划重点项目、某部委创新特区项目、航天员中心项目等课题10余项。曾获工信部创新/创业奖学金、博士研究生国家奖学金、电子设计大赛、计算机设计大赛等10余项奖项。
研究方向为特种移动/操作机器人运动控制与路径规划,研发了多款空地跨域机器人,移动操作机械臂,空间站飞行机器人等。相关研究成果在控制领域顶刊 IEEE TCYB,机器人领域权威期刊 IEEE TMECH、IEEE RAL等期刊上发表论文20余篇。
熟悉特种机器人结构设计、软硬件设计,运动控制、路径规划和识别感知算法,可指导电赛、智能车、海赛等创新创业类比赛。
部分研究成果:
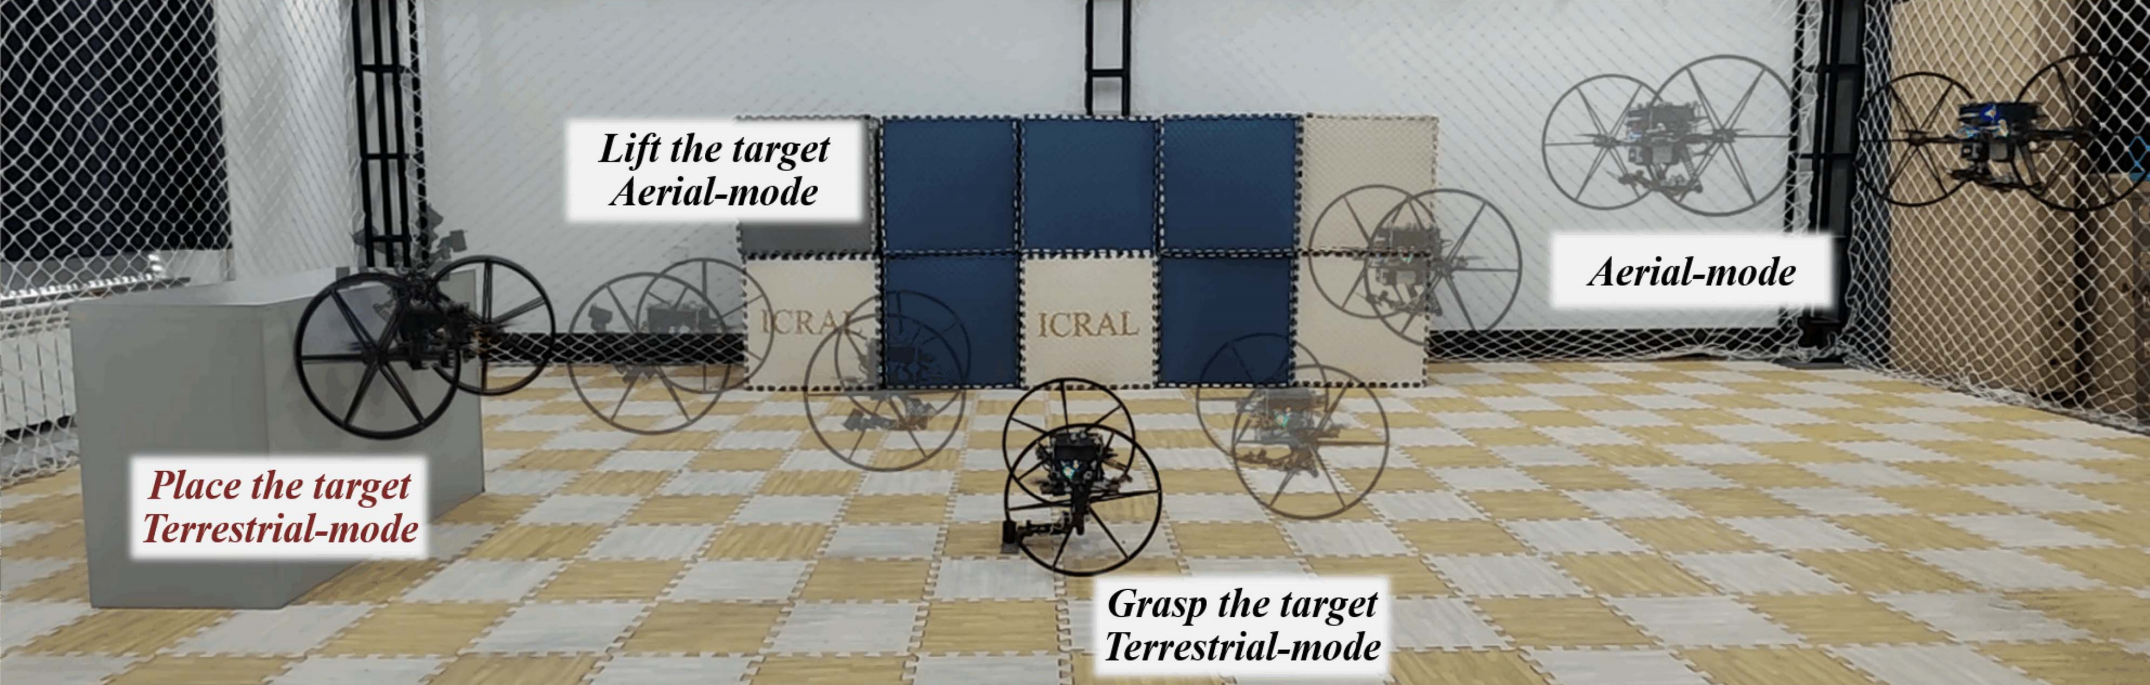
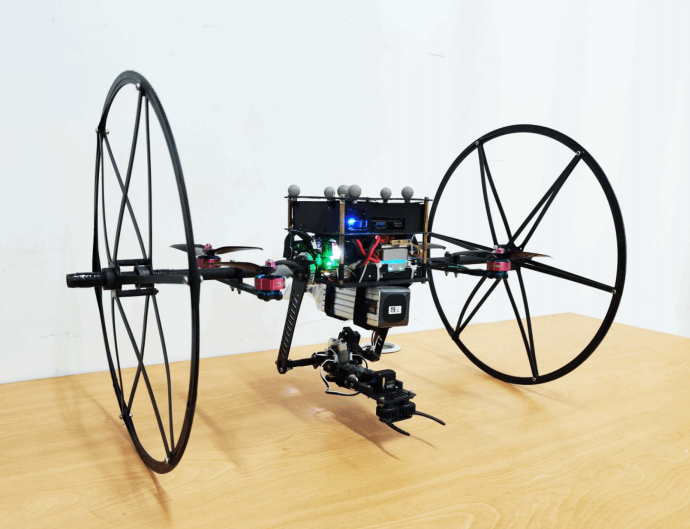
[1] 空地跨域移动操作机器人(公开):具备空/地/斜面多模态的运动能力和高精度操作能力。
[2] 特种无人机/车/船、空间站舱内飞行机器人等
代表性学术成果:
[1] Yihang Ding, et al, Smooth Control of Asynchronously Switched Fuzzy Systems With Partly Stochastic Sojourn Time, IEEE Transactions on Cybernetics, 2026.(Q1,顶刊)
[2] Yihang Ding, et al, Unified Aerial-Terrestrial-Inclined Path Search and Trajectory Optimization for Chat-PM, Science China Technological Sciences, 2025.(Q1,顶刊)
[3] Yihang Ding, et al,Contact-Oriented Path Planning and Force-Aware Control of a Fixed-Tilt Wrench-Actuated Aerial Manipulator, IEEE/ASME Transactions on Mechatronics (Q1,顶刊,under review)
[4] Yihang Ding, et al, Chat-PM: A Class of Composite Hybrid Aerial/Terrestrial Precise Manipulator, IEEE Robotics and Automation Letters, 2024.
[5] Yihang Ding, et al, Guaranteed Cost Control for A Class of Composite Hybrid Aerial/Terrestrial Precise Manipulator with Stochastic Switching Payloads. Optimal Control Applications and Methods, 2024.
[6] Yihang Ding, et al,Vehicle-manipulator motion planning method for Chat-PM in near-obstacle environments,SCIENCE CHINA Information Sciences, 2025.
[7] Yihang Ding, et al, Bumpless transfer control of Asynchronously Switched Linear Systems with Stochastic Mode-Dependent Sojourn-Time, Fully Actuated System Theory and Applications, 2025.
[8] Tong Wu, Yihang Ding, et al Efficient Model Predictive Control for Markov Jump Nonlinear Systems via Controllable Sets and Sum-of-Square Programming. IEEE Control Systems Letters, 2024.
[9] Chengzhe Han, Lixian Zhang, Yihang Ding, et al. Robust Control of Chat-PM: A Switched Singular System with Mode-dependent Bounded Nonlinearity. Aerospace Science and Technology, 2024.
[10] Bo Cai, Kaixin Xu, Yihang Ding, et al, Observer-based control for switched systems with limited statistical information, IEEE Transactions on Systems, Man, and Cybernetics: Systems,2026.